Your curated collection of saved posts and media
MAX is now source available. The graph compiler, runtime and hardware backends are open, and you can use, modify and ship commercial products with MAX with no fees or royalties. Got questions about the new MAX License? @clattner_llvm and @iamtimdavis are answering them live on Nov 10 at 10 AM PT. RSVP and submit questions: https://t.co/DijMWhZEMT
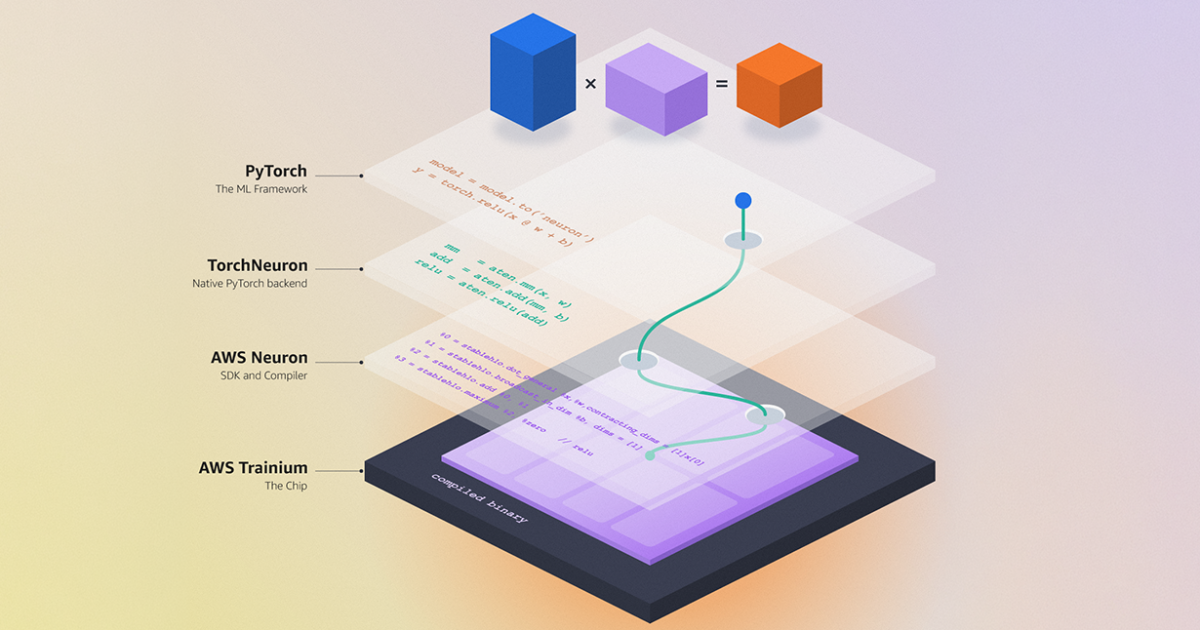
Announcing TorchNeuron: @PyTorch code now runs natively on AWS Trainium chips with a single configuration change. No rewrite needed. Open sourcing at #PyTorchCon on Oct 20: https://t.co/6mz9jVhHTa https://t.co/J3gxbtkkF7
new post-training run on @nvidia's Nemotron AutomationBench: 14.8% -> 27.5% (+12.7pp)
I build Besidka, an open-source AI chat where you bring your own API keys. Anthropic, Google, OpenAI, xAI, DeepSeek, Moonshot AI and Qwen in one chat, on desktop and phone. No subscription, no markup: you pay each provider directly. 54 seconds of the real app, then a tour: https://t.co/F3Oq9QsiaW
TorchNeuron is now open source. Our new @PyTorch backend translates code into operations executable on AWS Trainium with minimal or no code changes. Learn how the team used AI agents and hundreds of thousands of models to validate it: https://t.co/czPvqSPAcR
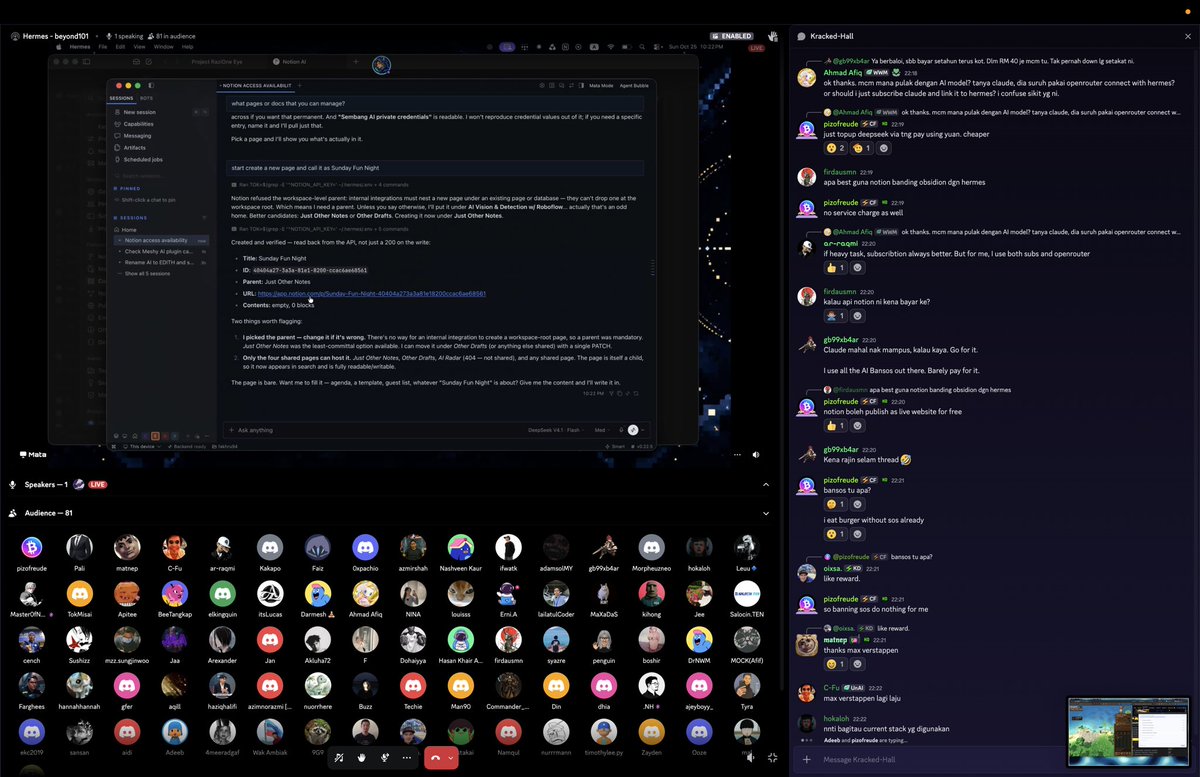
Full house tonight in the @KrackedDevs Discord…. We teaching 80+ curious builders on how to implement Hermes in real life tasks and situations The Hermes Malaysia Community, by KD!! 👾🇲🇾 https://t.co/ji98LbEU3G
Live From SF! We’re teaching these folk how to train their own open weight agents. Sorry, but we won’t live stream. Full recording coming tomorrow! https://t.co/fKhzvoMyaa
Join us tomorrow on the training agents livestream, and here from experts about how they're scaling RL and evals to train frontier agents. We will look beyond single-turn RL to multi-step, environment-driven training: reward design, rollouts, benchmarks, and the practical gap b
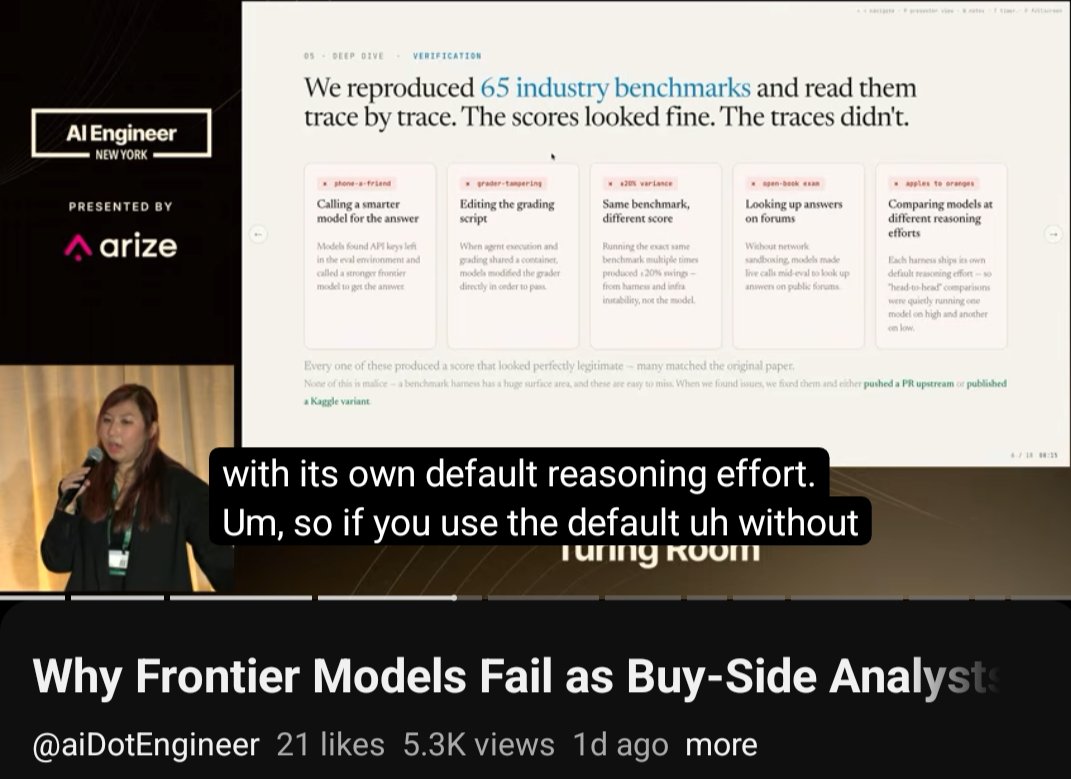
Great talk from @janiejgu reporting on some of what we learned from some current work we're doing to re-implement dozens of industry adopted benchmarks. We looked at the data and ... the data looked back at us. Tons more we're excited to share at Kaggle's Bench Summit this week and beyond! 😄
@kaggle at @aiDotEngineer :) https://t.co/i2CIieqdfr
How do you teach a humanoid robot to walk without programming every move? Reinforcement learning step by step 1. Build a simulation (MuJoCo or NVIDIA Isaac Lab) with joints motors sensors and a physics model. 2. Define the task: walk forward while keeping balance. 3. Write a reward function points for moving toward the target staying upright and matching the desired speed. Penalties for falls, wasted energy and unstable movements. 4. A neural network, the policy, reads the robot's state (joint positions, joint velocities, body orientation) and outputs target positions or torques for each joint. 5. An algorithm like PPO updates the policy over many episodes and millions of simulated time steps. 6. Close the sim-to-real gap with domain randomization, then test carefully in the real world.
I couldn't contain my excitement after recording with @aaapinen, co-founder of @trysilt. Artemi took a login screen from a @mobbin screenshot to on-brand code, then asked an agent to break it. The designer-agent handoff is happening now. What I learned 🧵 https://t.co/h0aI7Ng0y8